@inproceedings{nye2026struc,title={Structured Perception Representations for Off-road Dynamics Learning},author={Nye, Micah and Triest, Samuel and Sivaprakasam, Matthew and Adu, Isaiah and Scherer, Sebastian and Wang, Wenshan},booktitle={Conference on Robot Learning (CoRL)},year={2026},month=nov,eprint={2610.22900},archiveprefix={arXiv},primaryclass={cs.RO},url={https://arxiv.org/abs/2610.22900},}
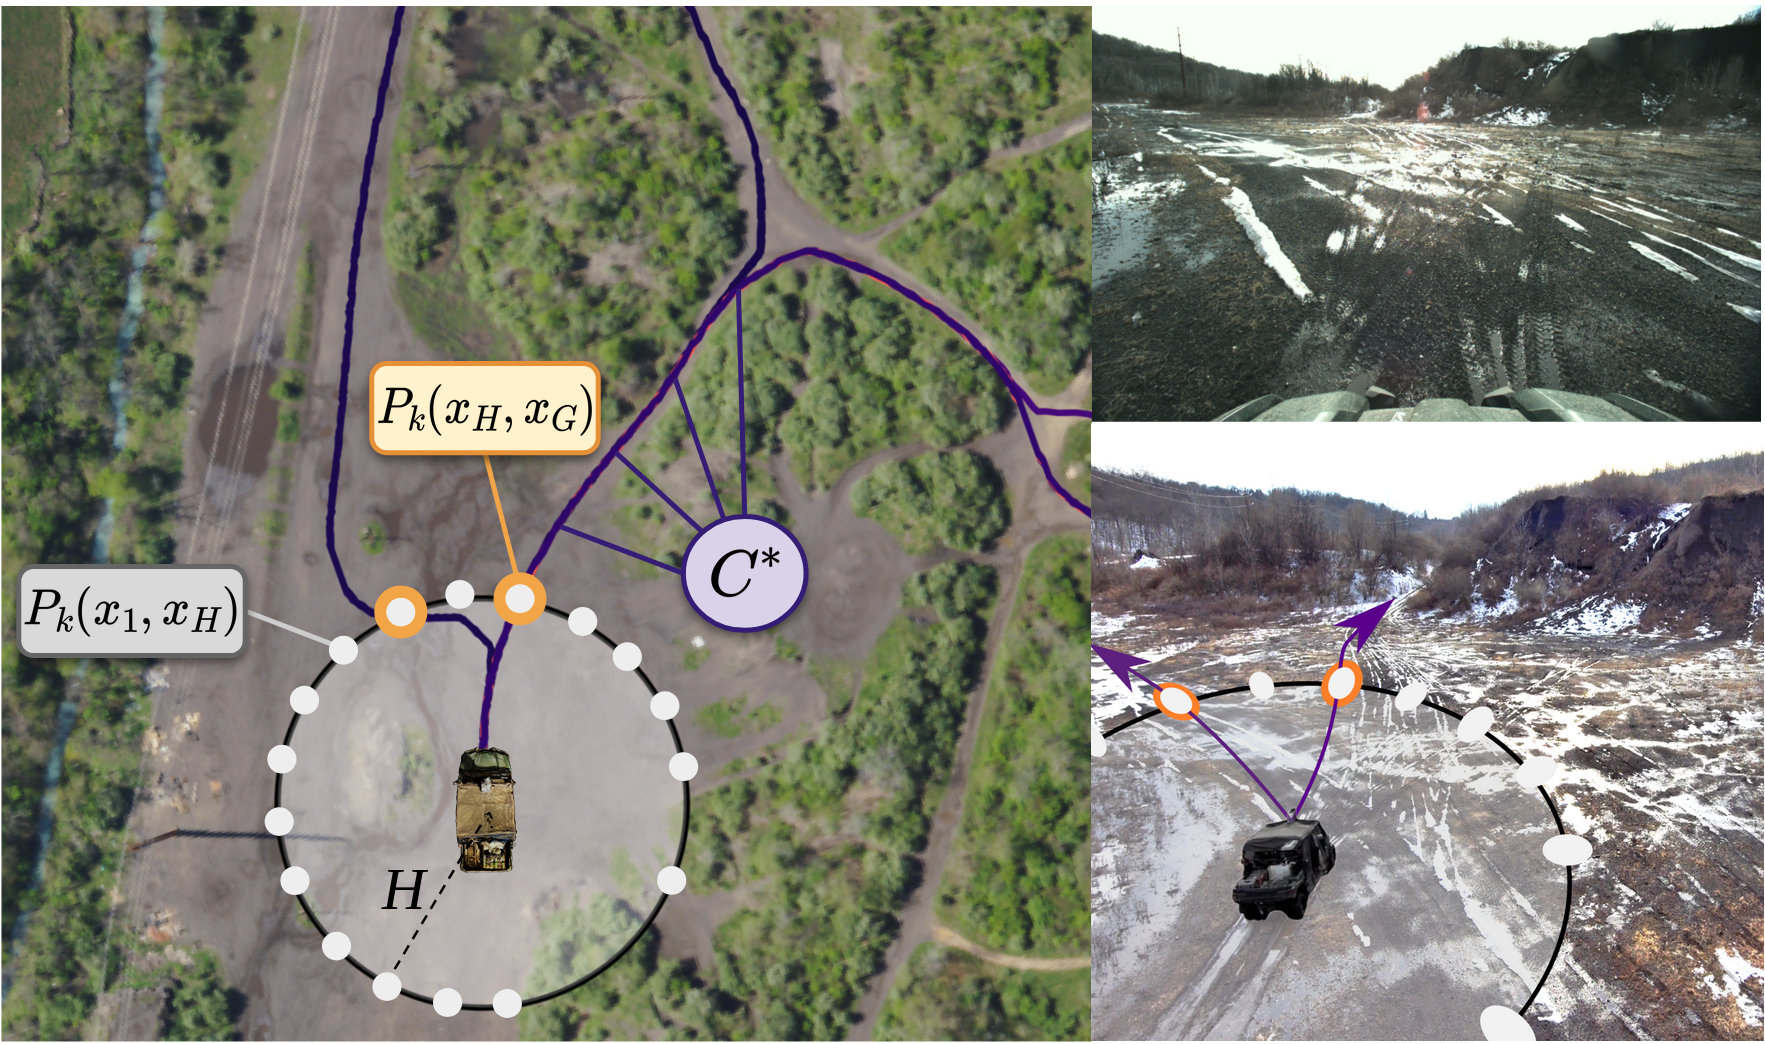
Distilling Global Traversability Priors for Image-based Affordance Prediction in Off-road Environments
Matthew Sivaprakasam, Samuel Triest, Micah Nye, and 5 more authors
In IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2026
@inproceedings{sivaprakasam2026distilling,title={Distilling Global Traversability Priors for Image-based Affordance Prediction in Off-road Environments},author={Sivaprakasam, Matthew and Triest, Samuel and Nye, Micah and Atha, Deegan and Khattak, Shehryar and Fan, David and Wang, Wenshan and Scherer, Sebastian},booktitle={IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)},year={2026},month=sep,eprint={2607.17984},archiveprefix={arXiv},primaryclass={cs.RO},url={https://arxiv.org/abs/2607.17984},}
A Quantitative Analysis of Undergraduate Researchers’ Intent to Apply to Graduate School
R. Burcin, Micah Nye, I. Adu, and 2 more authors
In IEEE World Engineering Education Conference (EDUNINE), 2026
@inproceedings{nye2026weec,title={A Quantitative Analysis of Undergraduate Researchers' Intent to Apply to Graduate School},author={Burcin, R. and Nye, Micah and Adu, I. and Mruthyunjaya, V. and Dolan, J. M.},booktitle={IEEE World Engineering Education Conference (EDUNINE)},year={2026},month=mar,url={https://ieeexplore.ieee.org/abstract/document/11546908},}
2025
BETTY Dataset: A Multi-modal Dataset for Full-Stack Autonomy
Micah Nye, A. Raji, Andrew Saba, and 9 more authors
In IEEE International Conference on Robotics and Automation (ICRA), 2025
@inproceedings{nye2025betty,title={{BETTY} Dataset: A Multi-modal Dataset for Full-Stack Autonomy},author={Nye, Micah and Raji, A. and Saba, Andrew and Erlich, E. and Exley, R. and Goyal, A. and Matros, A. and Misra, R. and Sivaprakasam, Matthew and Bertogna, M. and Ramanan, Deva and Scherer, Sebastian},booktitle={IEEE International Conference on Robotics and Automation (ICRA)},year={2025},pages={2453--2460},doi={10.1109/ICRA55743.2025.11127350},url={https://arxiv.org/abs/2505.07266v1},}
2024
TartanDrive 2.0: More Modalities and Better Infrastructure to Further Self-Supervised Learning Research in Off-Road Driving Tasks
Matthew Sivaprakasam, Parv Maheshwari, Mateo Guaman Castro, and 6 more authors
In IEEE International Conference on Robotics and Automation (ICRA), 2024
@inproceedings{sivaprakasam2024tartandrive2,title={{TartanDrive} 2.0: More Modalities and Better Infrastructure to Further Self-Supervised Learning Research in Off-Road Driving Tasks},author={Sivaprakasam, Matthew and Maheshwari, Parv and Castro, Mateo Guaman and Triest, Samuel and Nye, Micah and Willits, S. and Saba, Andrew and Wang, Wenshan and Scherer, Sebastian},booktitle={IEEE International Conference on Robotics and Automation (ICRA)},year={2024},pages={12606},doi={10.1109/ICRA57147.2024.10611265},url={https://theairlab.org/TartanDrive2/assets/TartanDrive_2_0_ICRA_2024.pdf},}
Fast and Modular Autonomy Software for Autonomous Racing Vehicles
Andrew Saba, Aderotimi Adetunji, Adam Johnson, and 27 more authors
Field Robotics, 2024
now retitled as IEEE Transactions on Field Robotics
@article{saba2024racing,title={Fast and Modular Autonomy Software for Autonomous Racing Vehicles},author={Saba, Andrew and Adetunji, Aderotimi and Johnson, Adam and Kothari, Aadi and Sivaprakasam, Matthew and Spisak, Joshua and Bharatia, Prem and Chauhan, Arjun and Duff, Jr., Brendan and Gasparro, Noah and King, Charles and Larkin, Ryan and Mao, Brian and Nye, Micah and Parashar, Anjali and Attias, Joseph and Balciumas, Aurimas and Brown, Austin and Chang, Chris and Gao, Ming and Heredia, Cindy and Keats, Andrew and Lavariega, Jose and Muckleroy, III, William and Slavescu, Andre and Stathas, Nicholas and Suvarna, Nayana and Zhang, Cin Tuan and Scherer, Sebastian and Ramanan, Deva},journaltitle={Field Robotics},volume={4},pages={1--45},year={2024},doi={10.55417/fr.2024001},note={now retitled as IEEE Transactions on Field Robotics},url={https://ieeexplore.ieee.org/document/10876003},}
2023
Simulation and Control for Learning Collision-free Navigation for Aerial Vehicles
Micah Nye, Micah Corah, and Sebastian Scherer
Robotics Institute of Summer Scholars Working Papers Journal, 2023
@article{nye2023riss,title={Simulation and Control for Learning Collision-free Navigation for Aerial Vehicles},author={Nye, Micah and Corah, Micah and Scherer, Sebastian},journaltitle={Robotics Institute of Summer Scholars Working Papers Journal},volume={11},year={2023},url={https://drive.google.com/file/d/1ZlZ-vXaElgNgiJP2SVWEBw89i3ssk5hl/view?usp=share_link},}
TartanDrive 1.5: Improving Large Multimodal Robotics Dataset Collection and Distribution
Matthew Sivaprakasam, Samuel Triest, Mateo Guaman Castro, and 6 more authors
In IEEE International Conference on Robotics and Automation (ICRA) Workshop on Pretraining for Robotics (PT4R), 2023
@inproceedings{sivaprakasam2023tartandrive15,title={{TartanDrive} 1.5: Improving Large Multimodal Robotics Dataset Collection and Distribution},author={Sivaprakasam, Matthew and Triest, Samuel and Castro, Mateo Guaman and Nye, Micah and Maulimov, Mukhtar and Ho, Cherie and Maheshwari, Parv and Wang, Wenshan and Scherer, Sebastian},booktitle={IEEE International Conference on Robotics and Automation (ICRA) Workshop on Pretraining for Robotics (PT4R)},year={2023},keywords={workshop},url={https://openreview.net/forum?id=7Y1pnhFJUT},}